Jumpei Saito

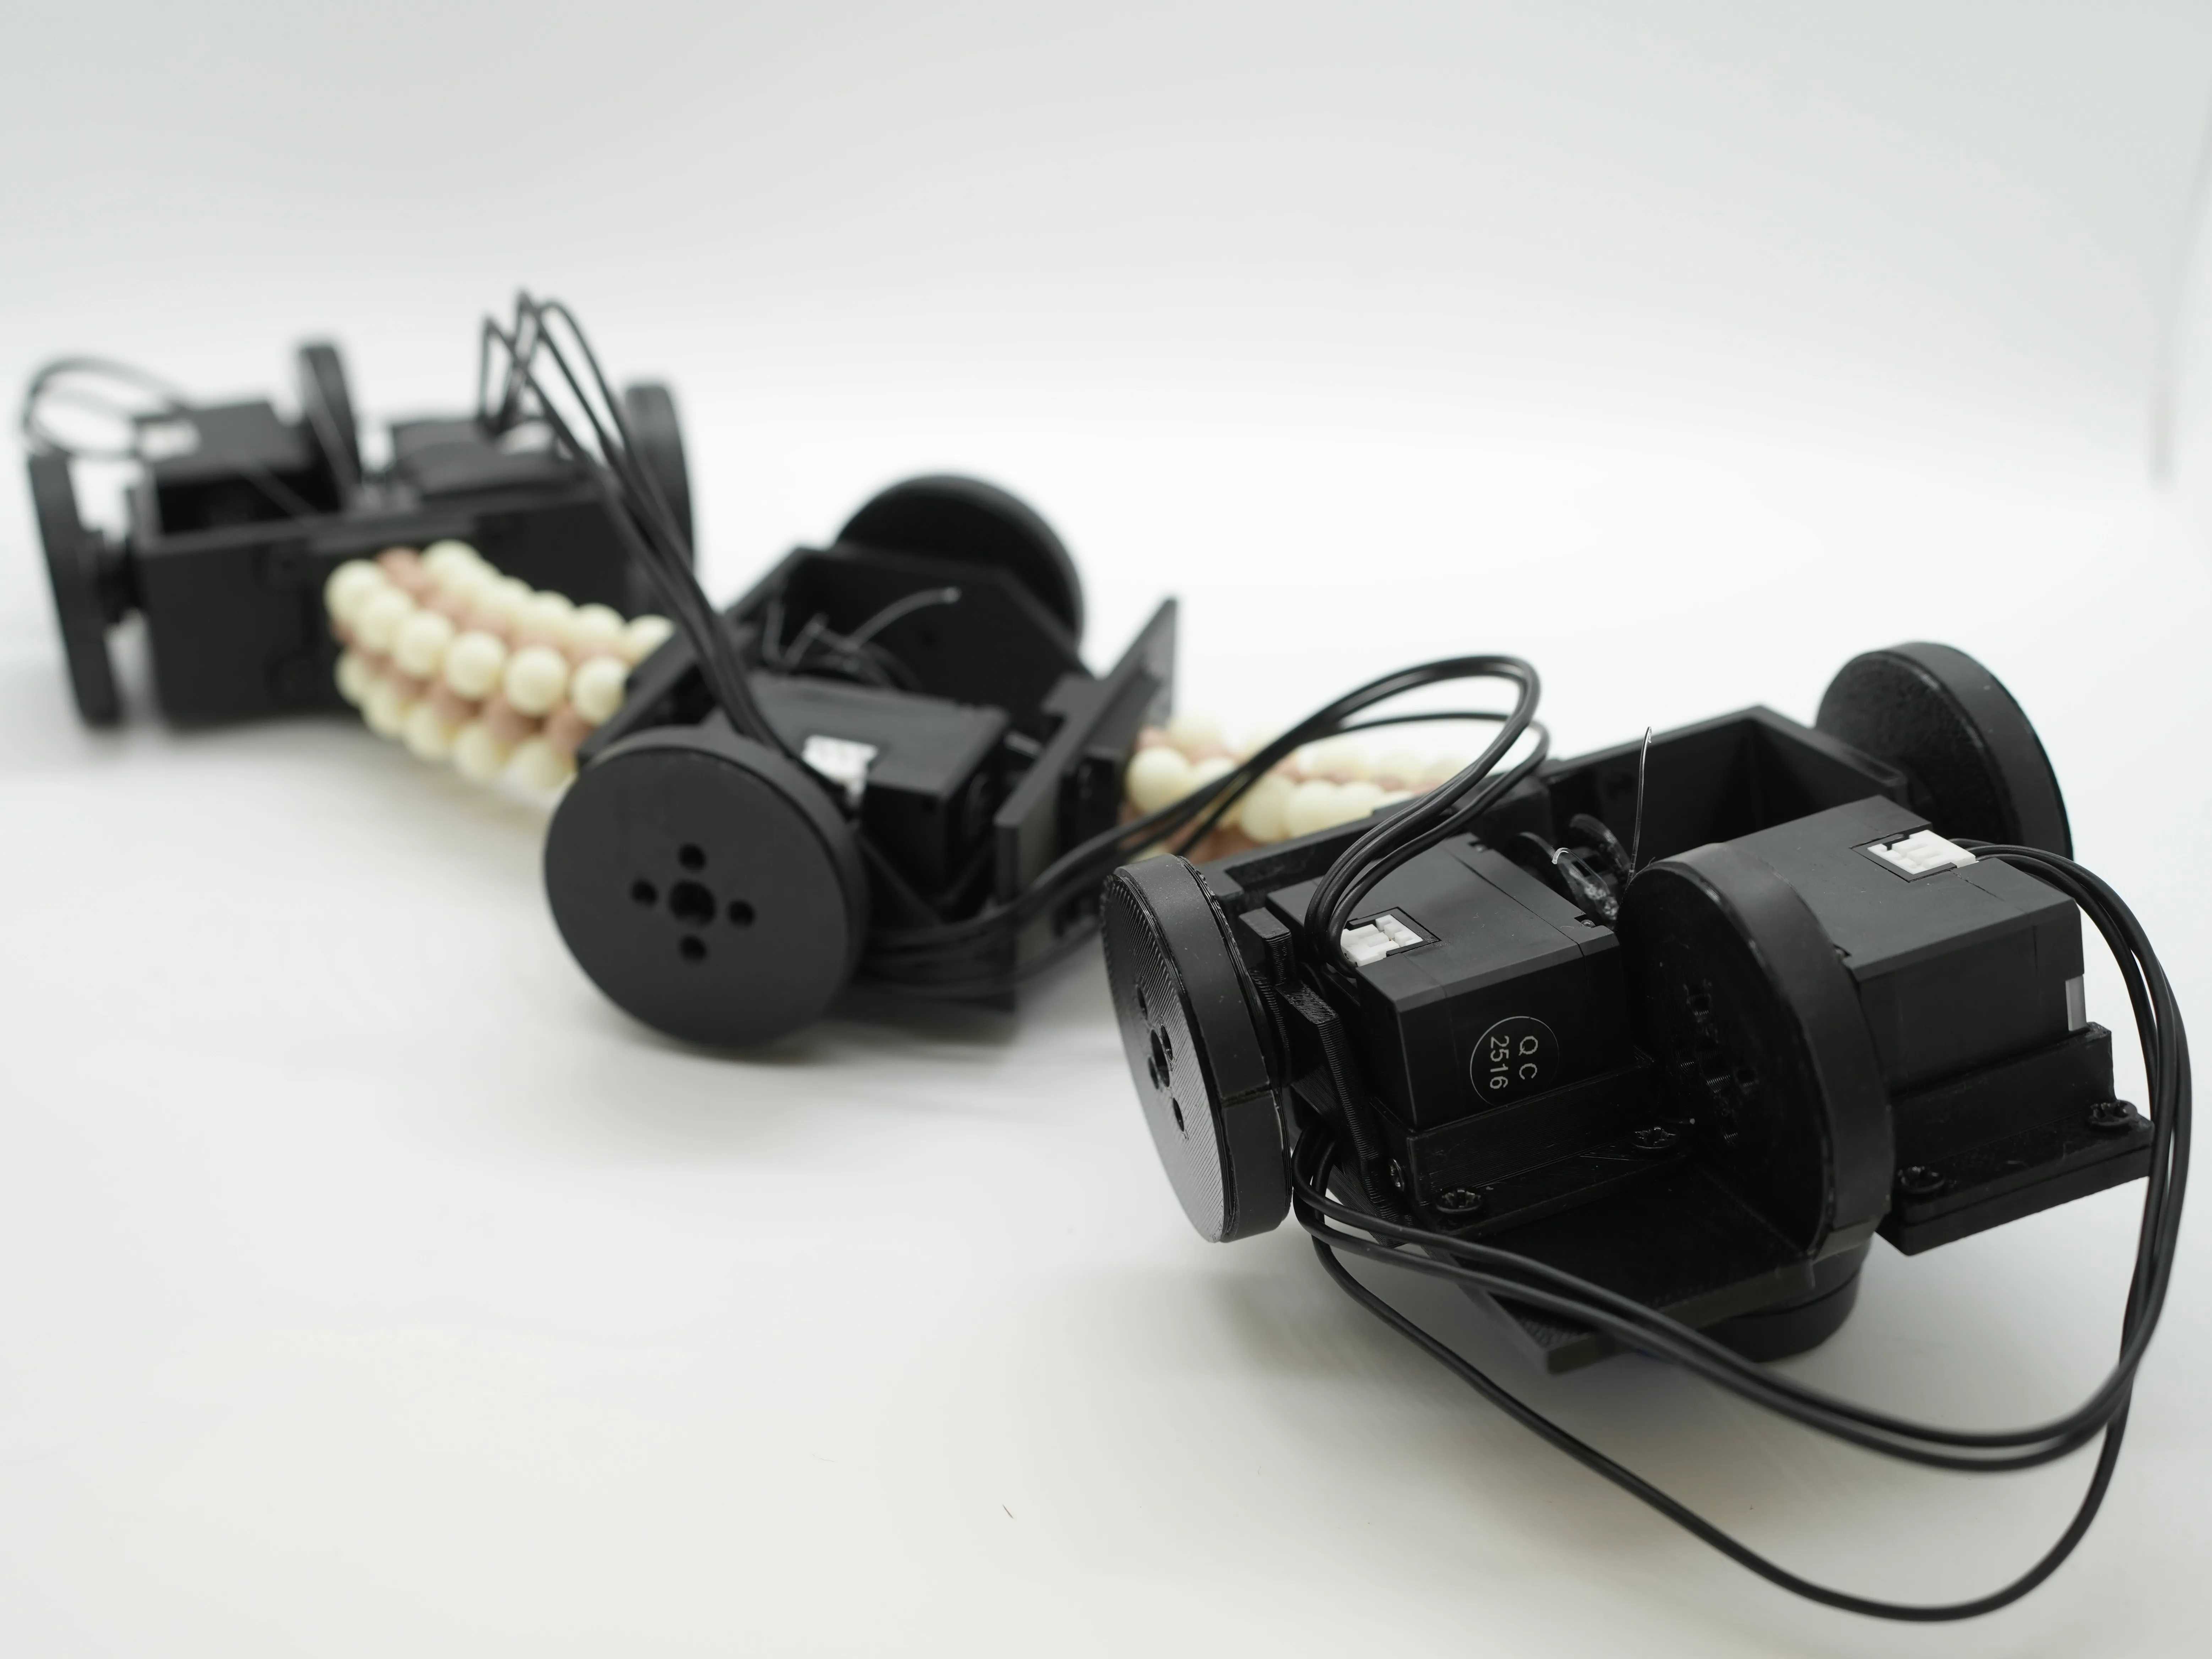
3つの車輪モジュールを2つのビーズ状スパインで接続した腱駆動移動ロボット

Beaded Spine Robot

Carnegie Mellon University でのサマーインターンシップで開発。

  • robotics
  • soft robotics
  • mobile robot
  • tendon-driven mechanism

2026年、Carnegie Mellon University Robotics InstituteのZoom Labでのサマーインターンシップで開発。

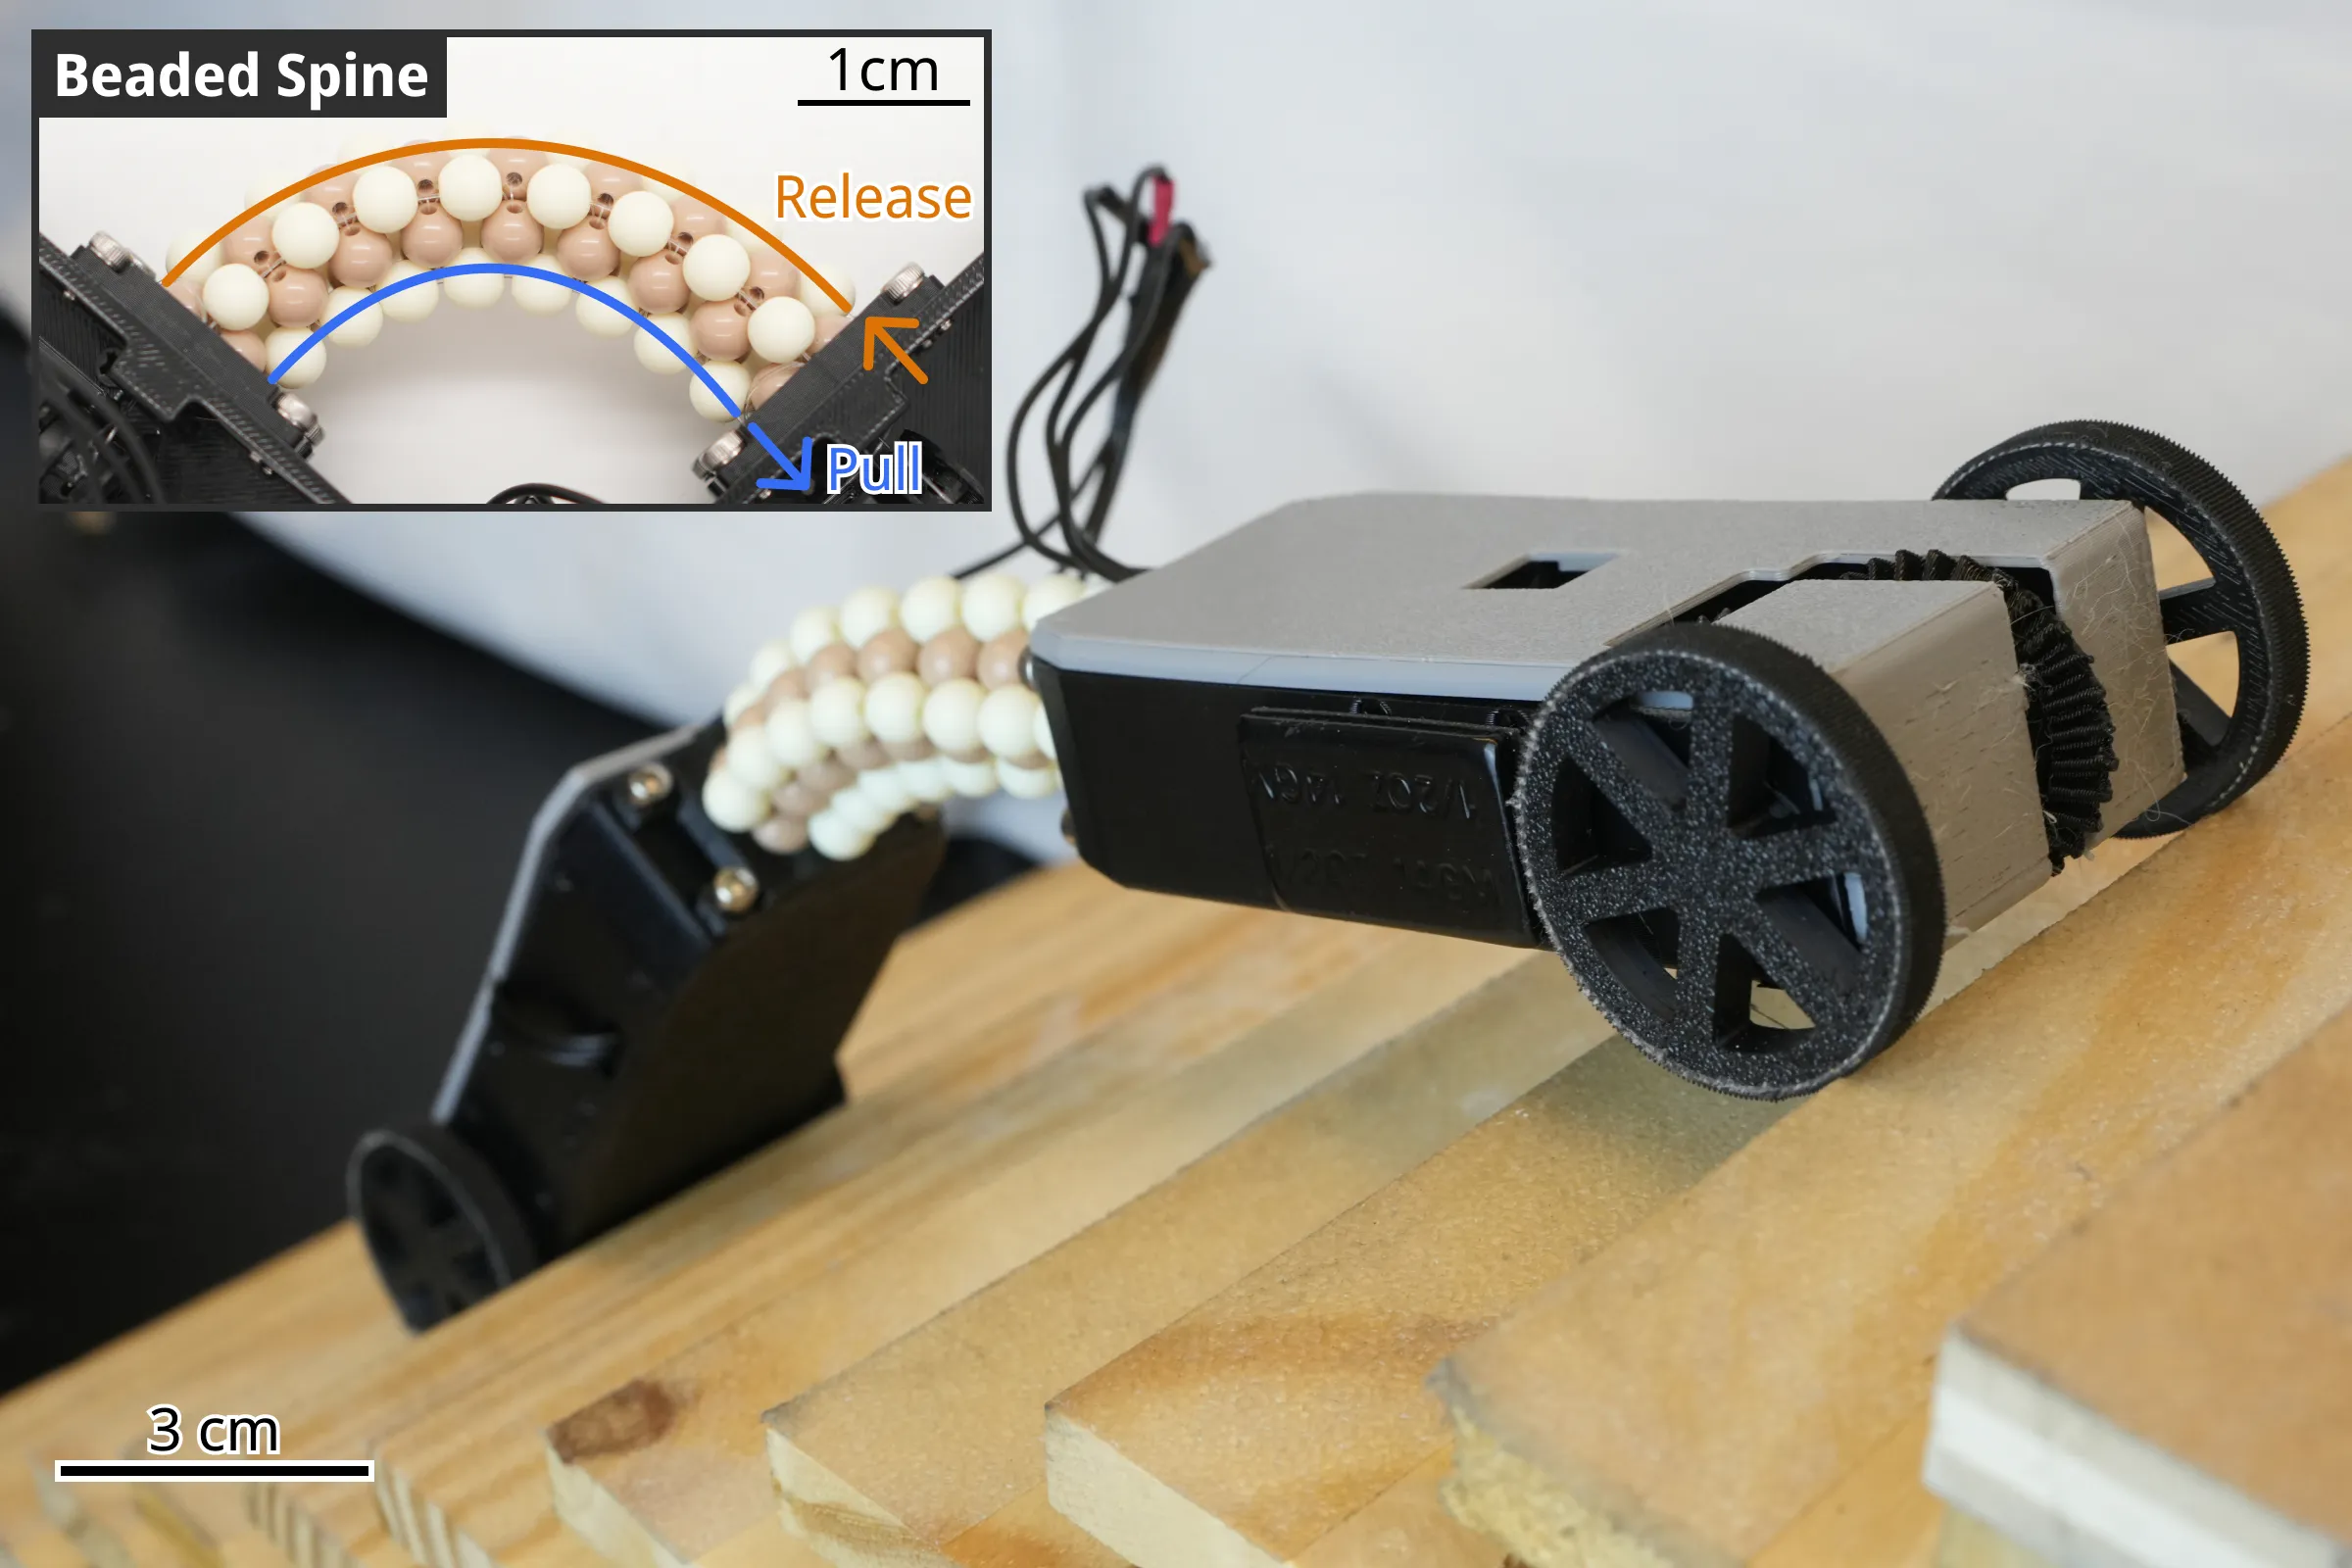
木製の段差を登るBaSiLと、腱の牽引によるビーズスパインの屈曲を示す拡大図

BaSiL: A Tendon-Driven Beaded Spine Robot for Shape-Adaptive Locomotion

Jumpei Saito, Rebecca Carpenter, Shashwat Singh, Zeynep Temel

Miniature Multiterrain and Multimodal Locomotion: from Biology to Robotics, IROS 2026 Workshop

  • Best Demo 3rd Prize
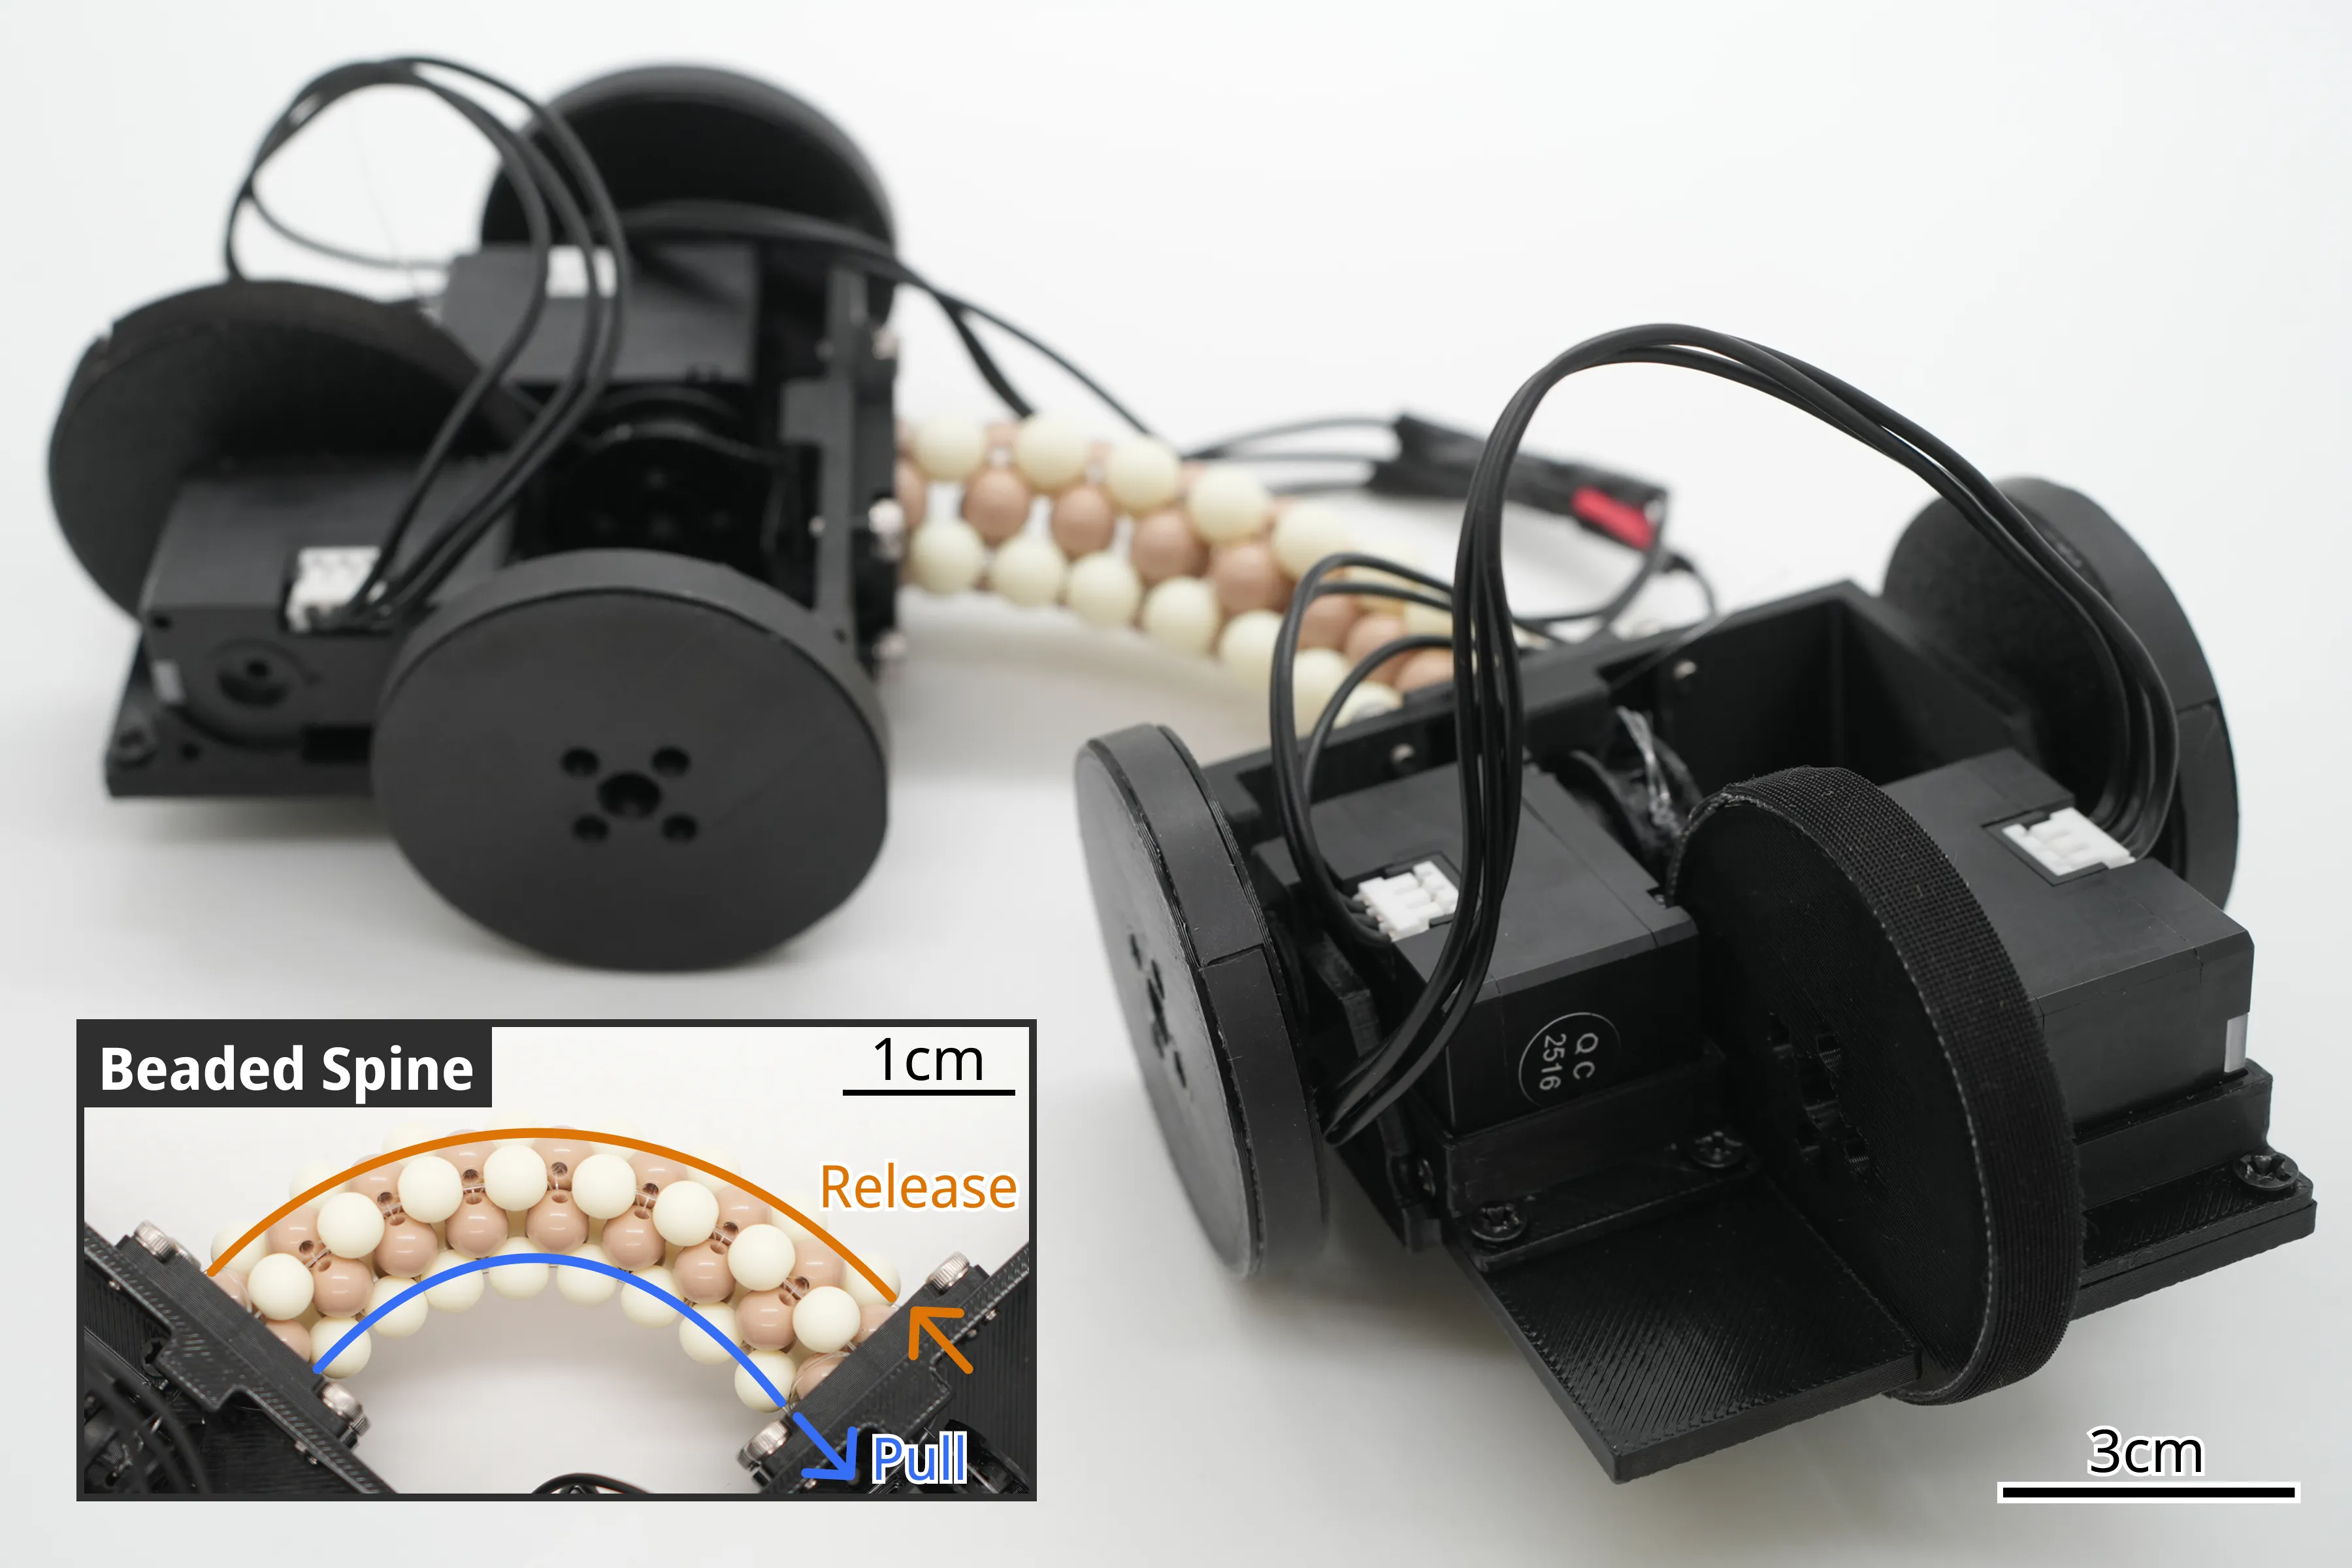
腱駆動ビーズスパインで接続した2モジュール車輪型ロボットと、腱によるスパイン屈曲を示す挿入図

A Tendon-Driven Beaded Spine Robot for Shape-Adaptive Locomotion

Jumpei Saito, Shashwat Singh, Rebecca Carpenter, Zeynep Temel

When Muscles Think: The Embodied Intelligence of Biological and Robotic Actuation, IROS 2026 Workshop
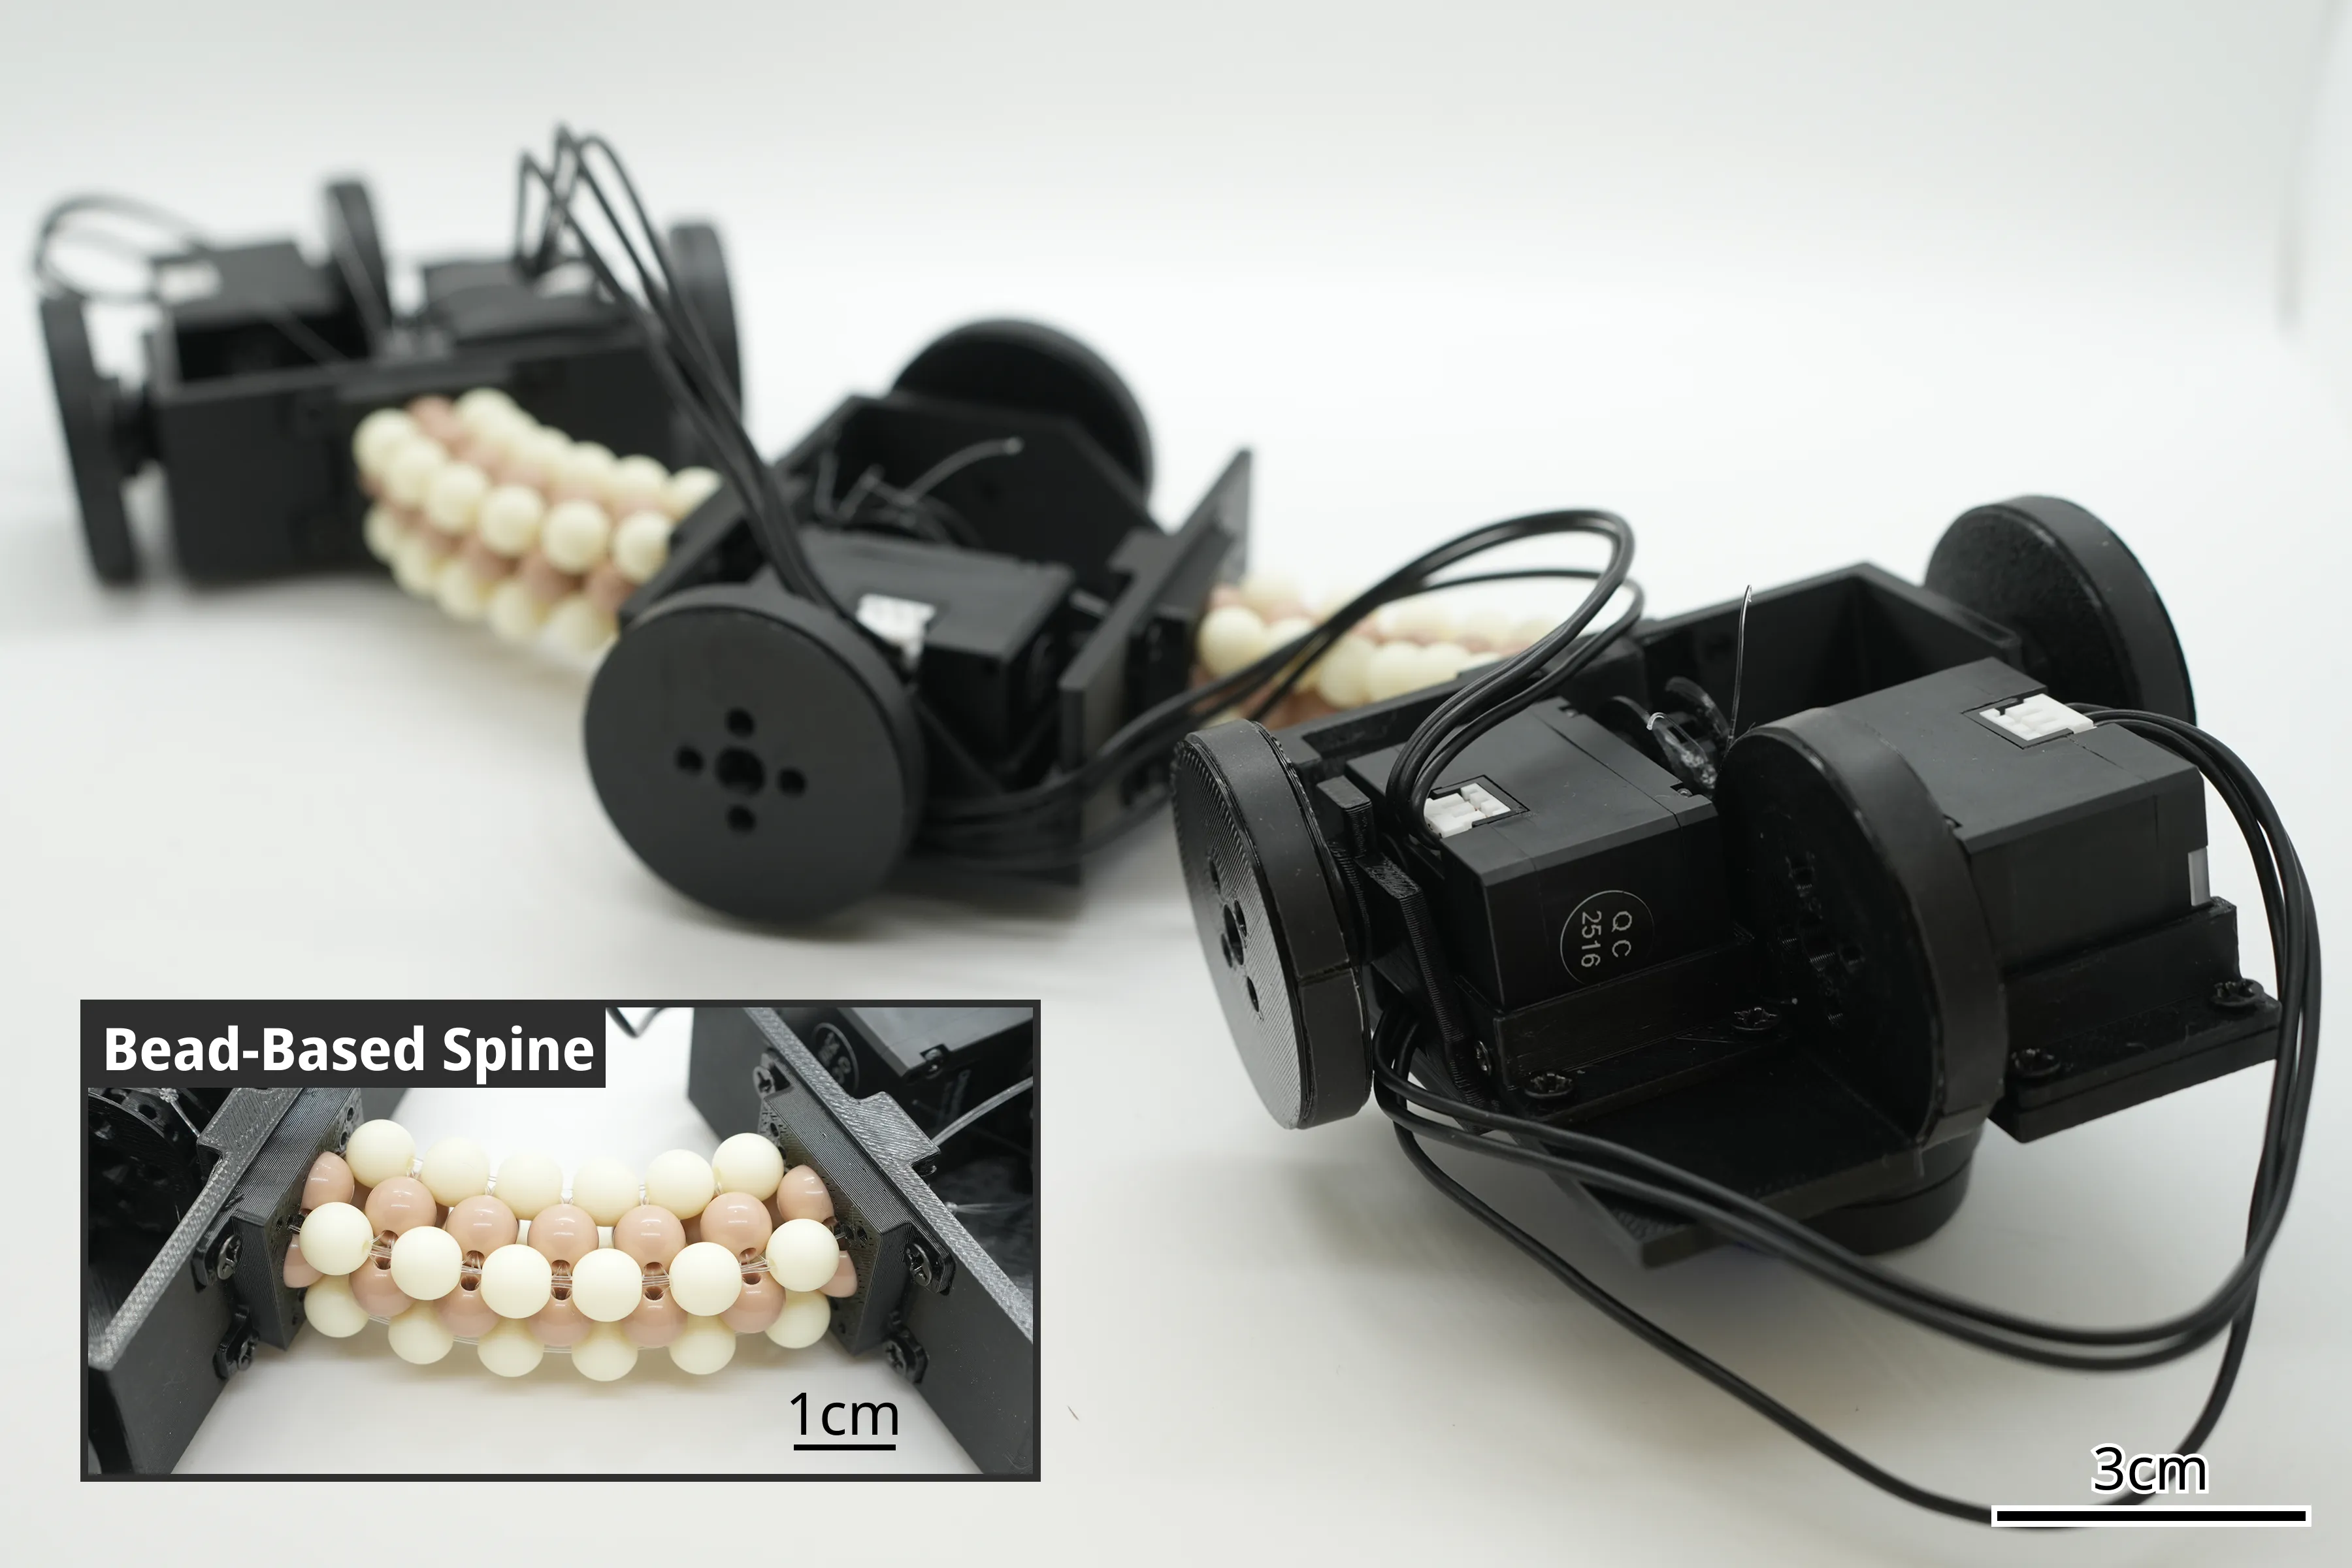
3つの車輪モジュールを2つのビーズ状スパインで接続した腱駆動移動ロボット

A Tendon-Driven Bead-Based Spine for Shape Adaptive Mobile Robot

Jumpei Saito, Shashwat Singh, Becca Carpenter, Zeynep Temel

Robotics Institute Summer Scholars (RISS) 2026