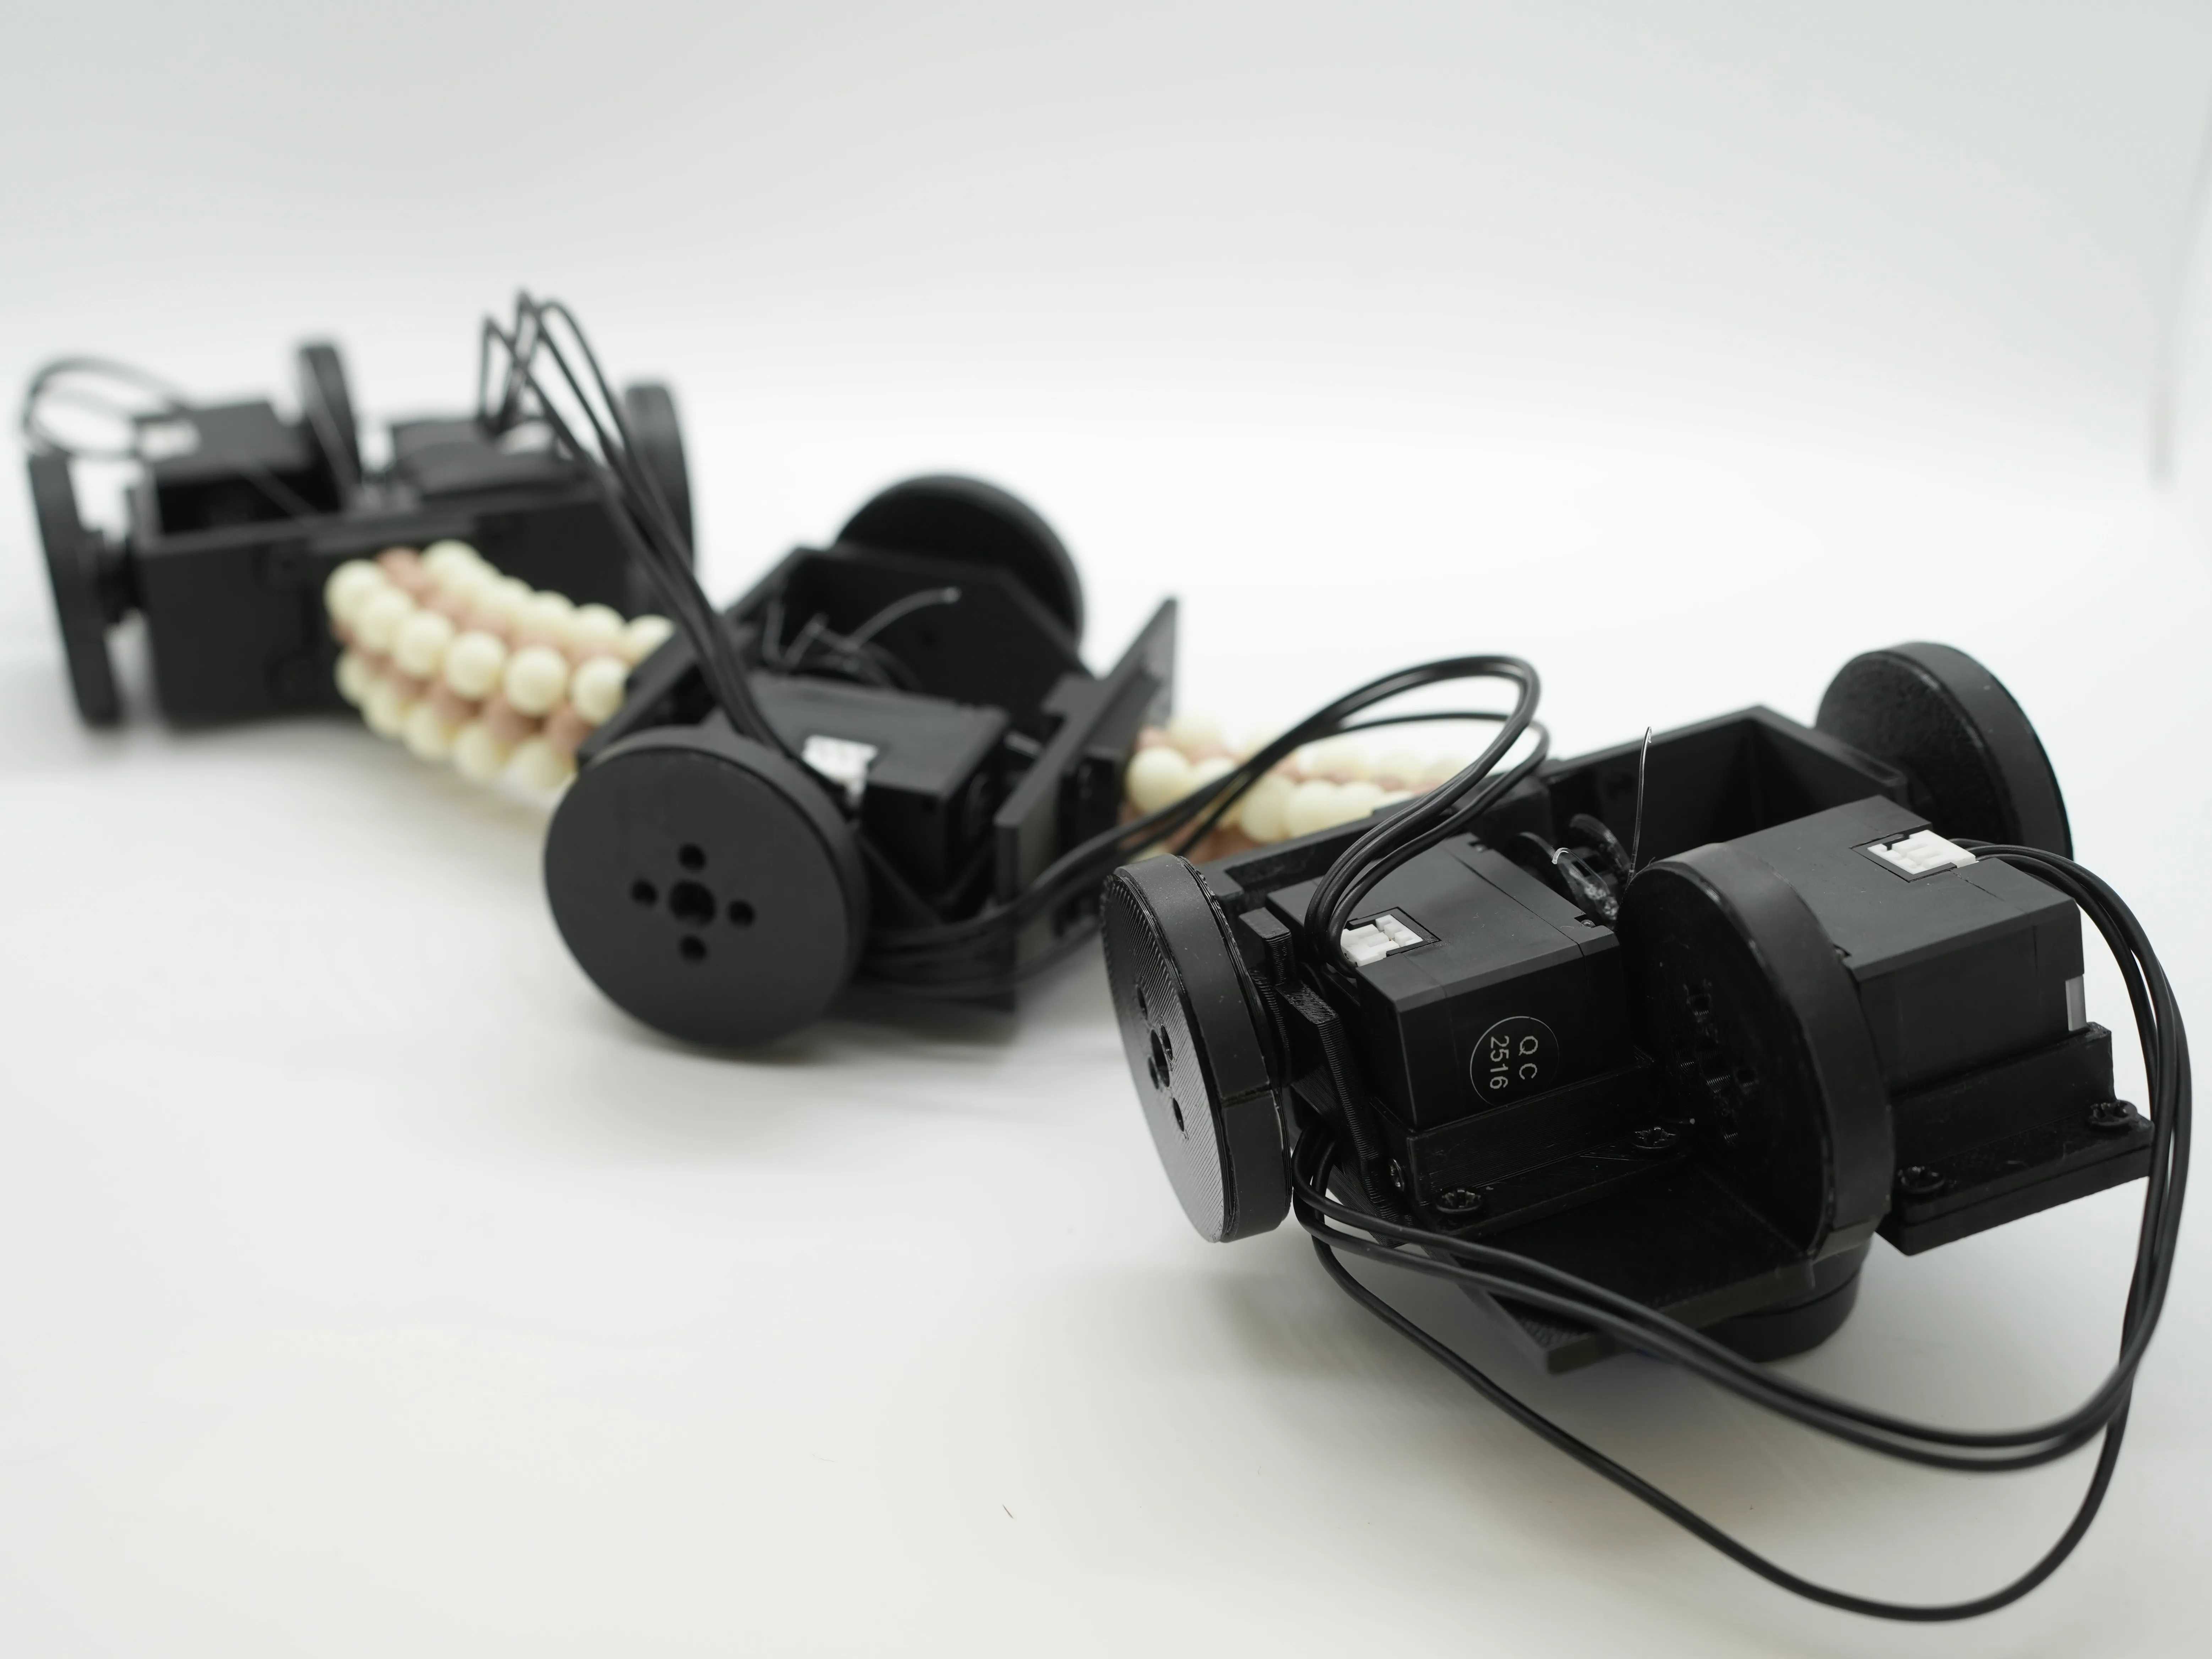
Beaded Spine Robot
Developed during a summer internship at Carnegie Mellon University's Robotics Institute.
Developed during a summer internship at the Zoom Lab in Carnegie Mellon University’s Robotics Institute in 2026.
Related publications
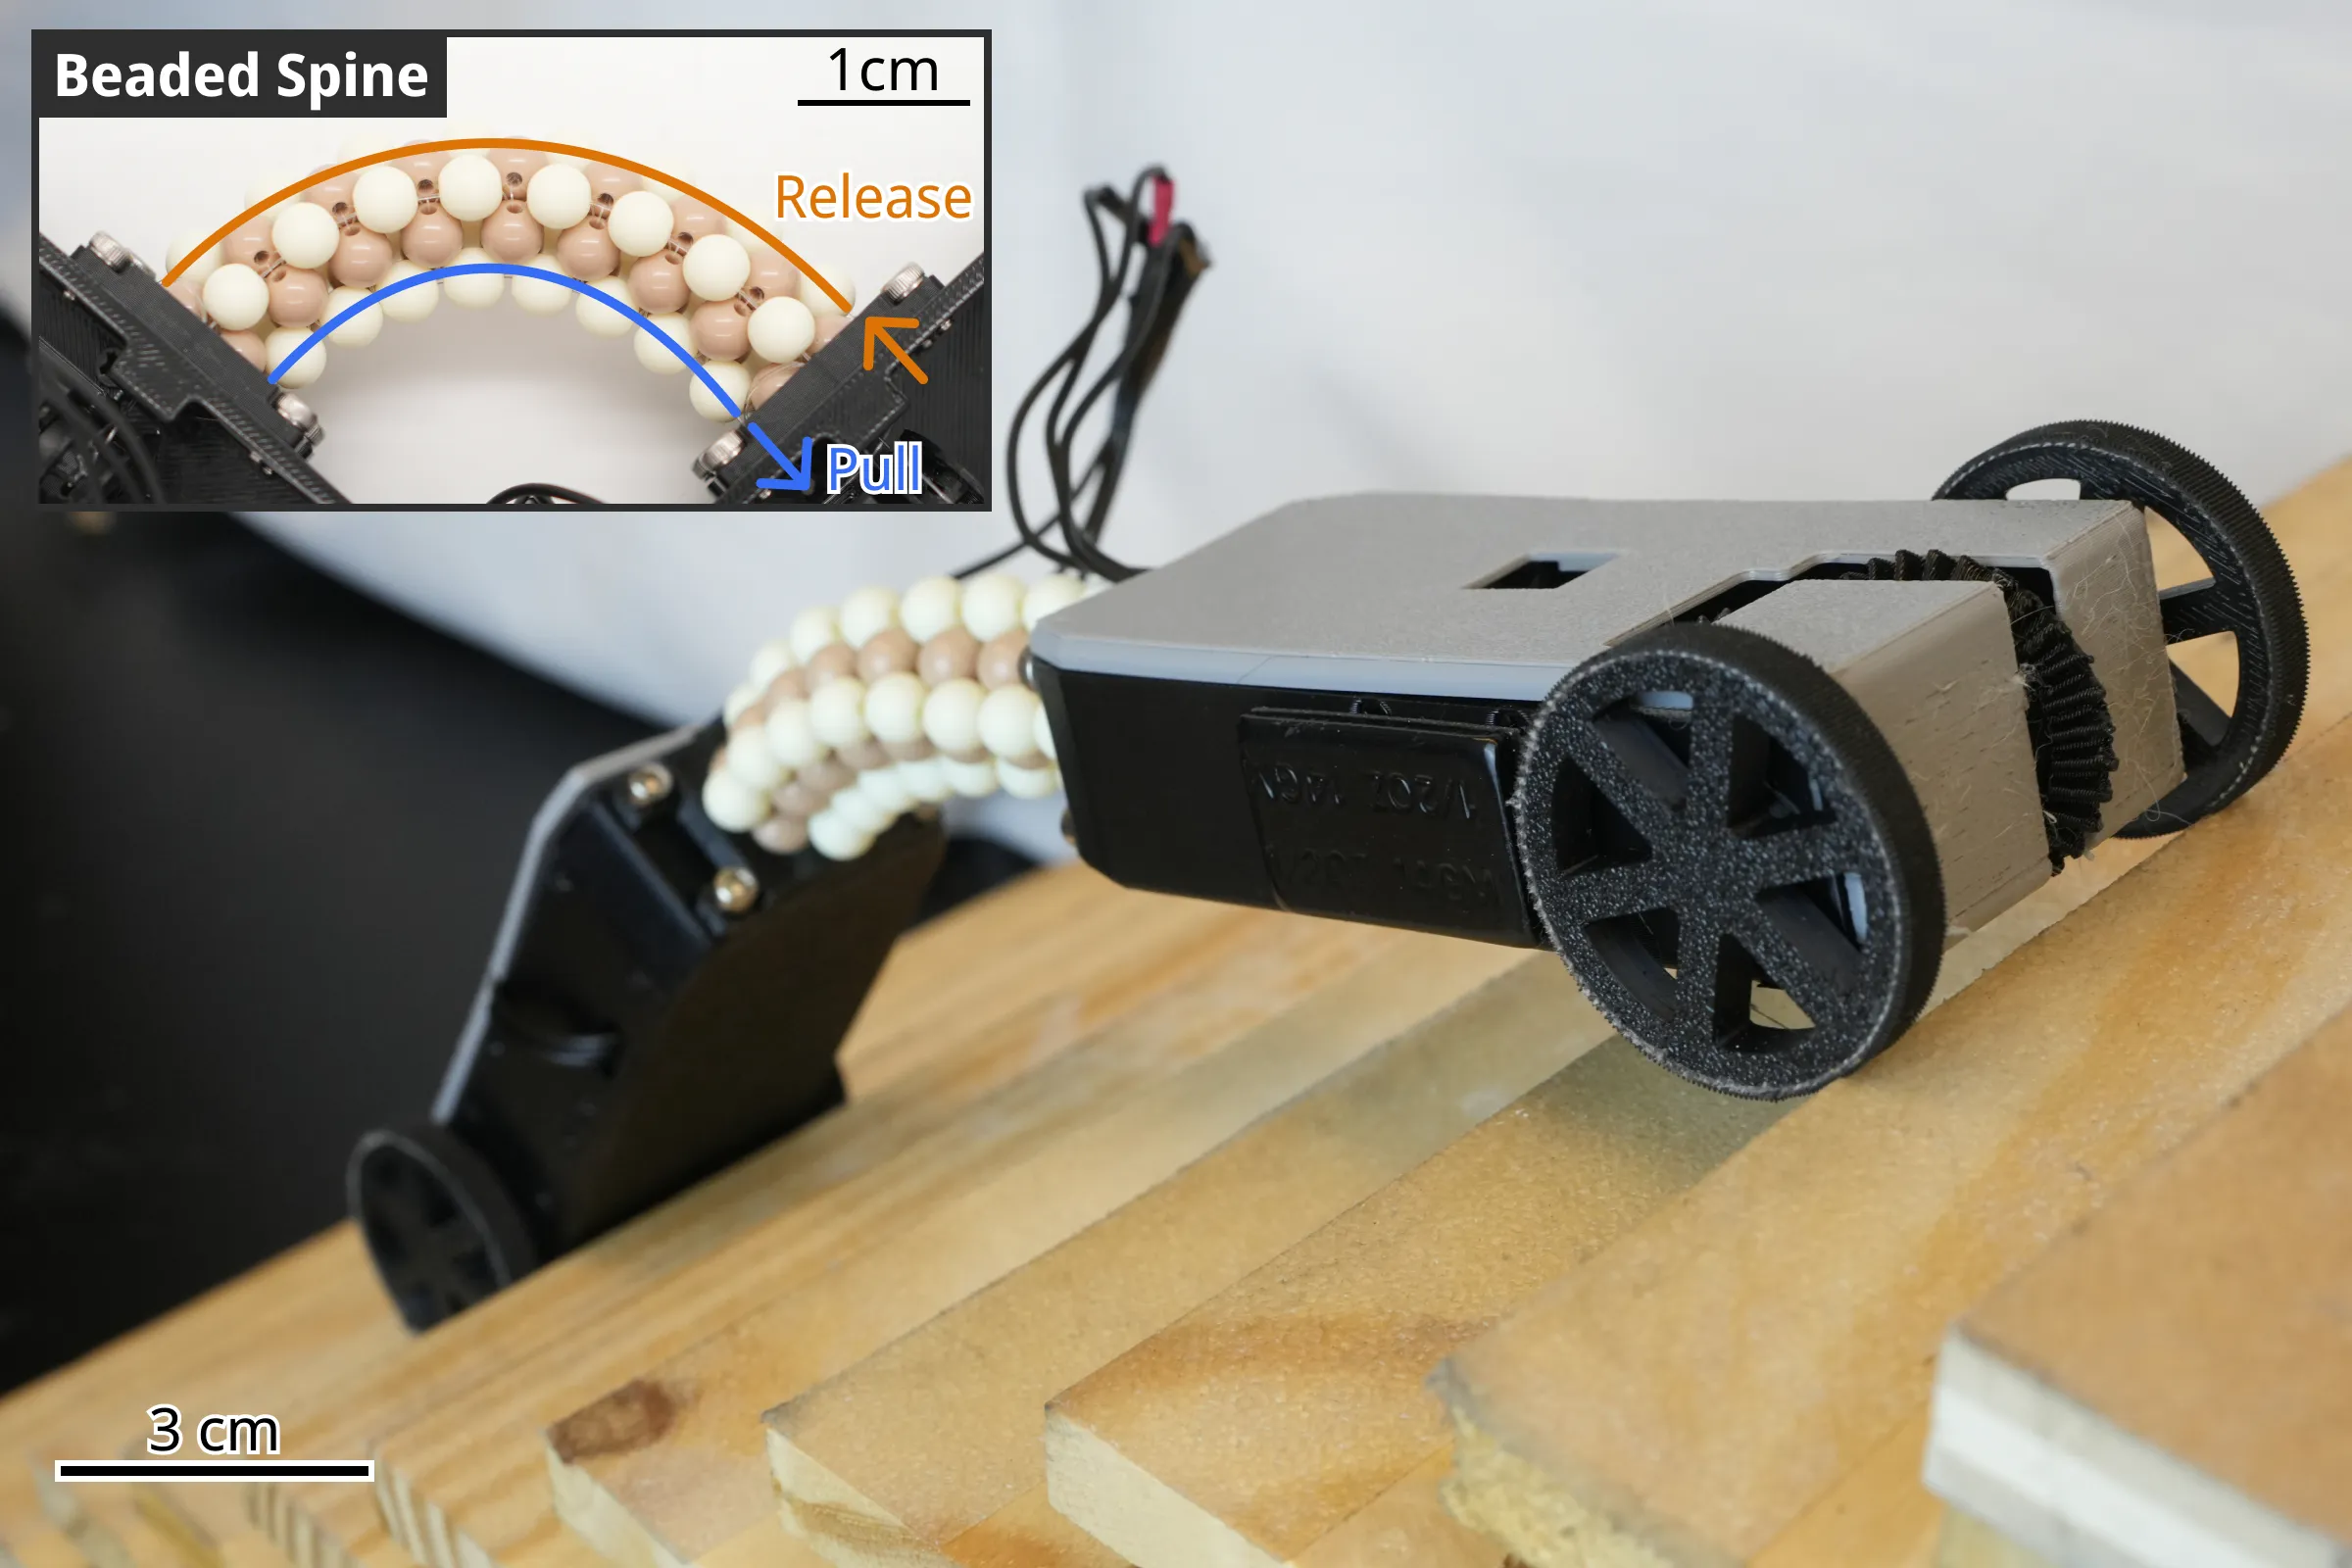
BaSiL: A Tendon-Driven Beaded Spine Robot for Shape-Adaptive Locomotion
Miniature Multiterrain and Multimodal Locomotion: from Biology to Robotics, IROS 2026 Workshop
- Best Demo 3rd Prize
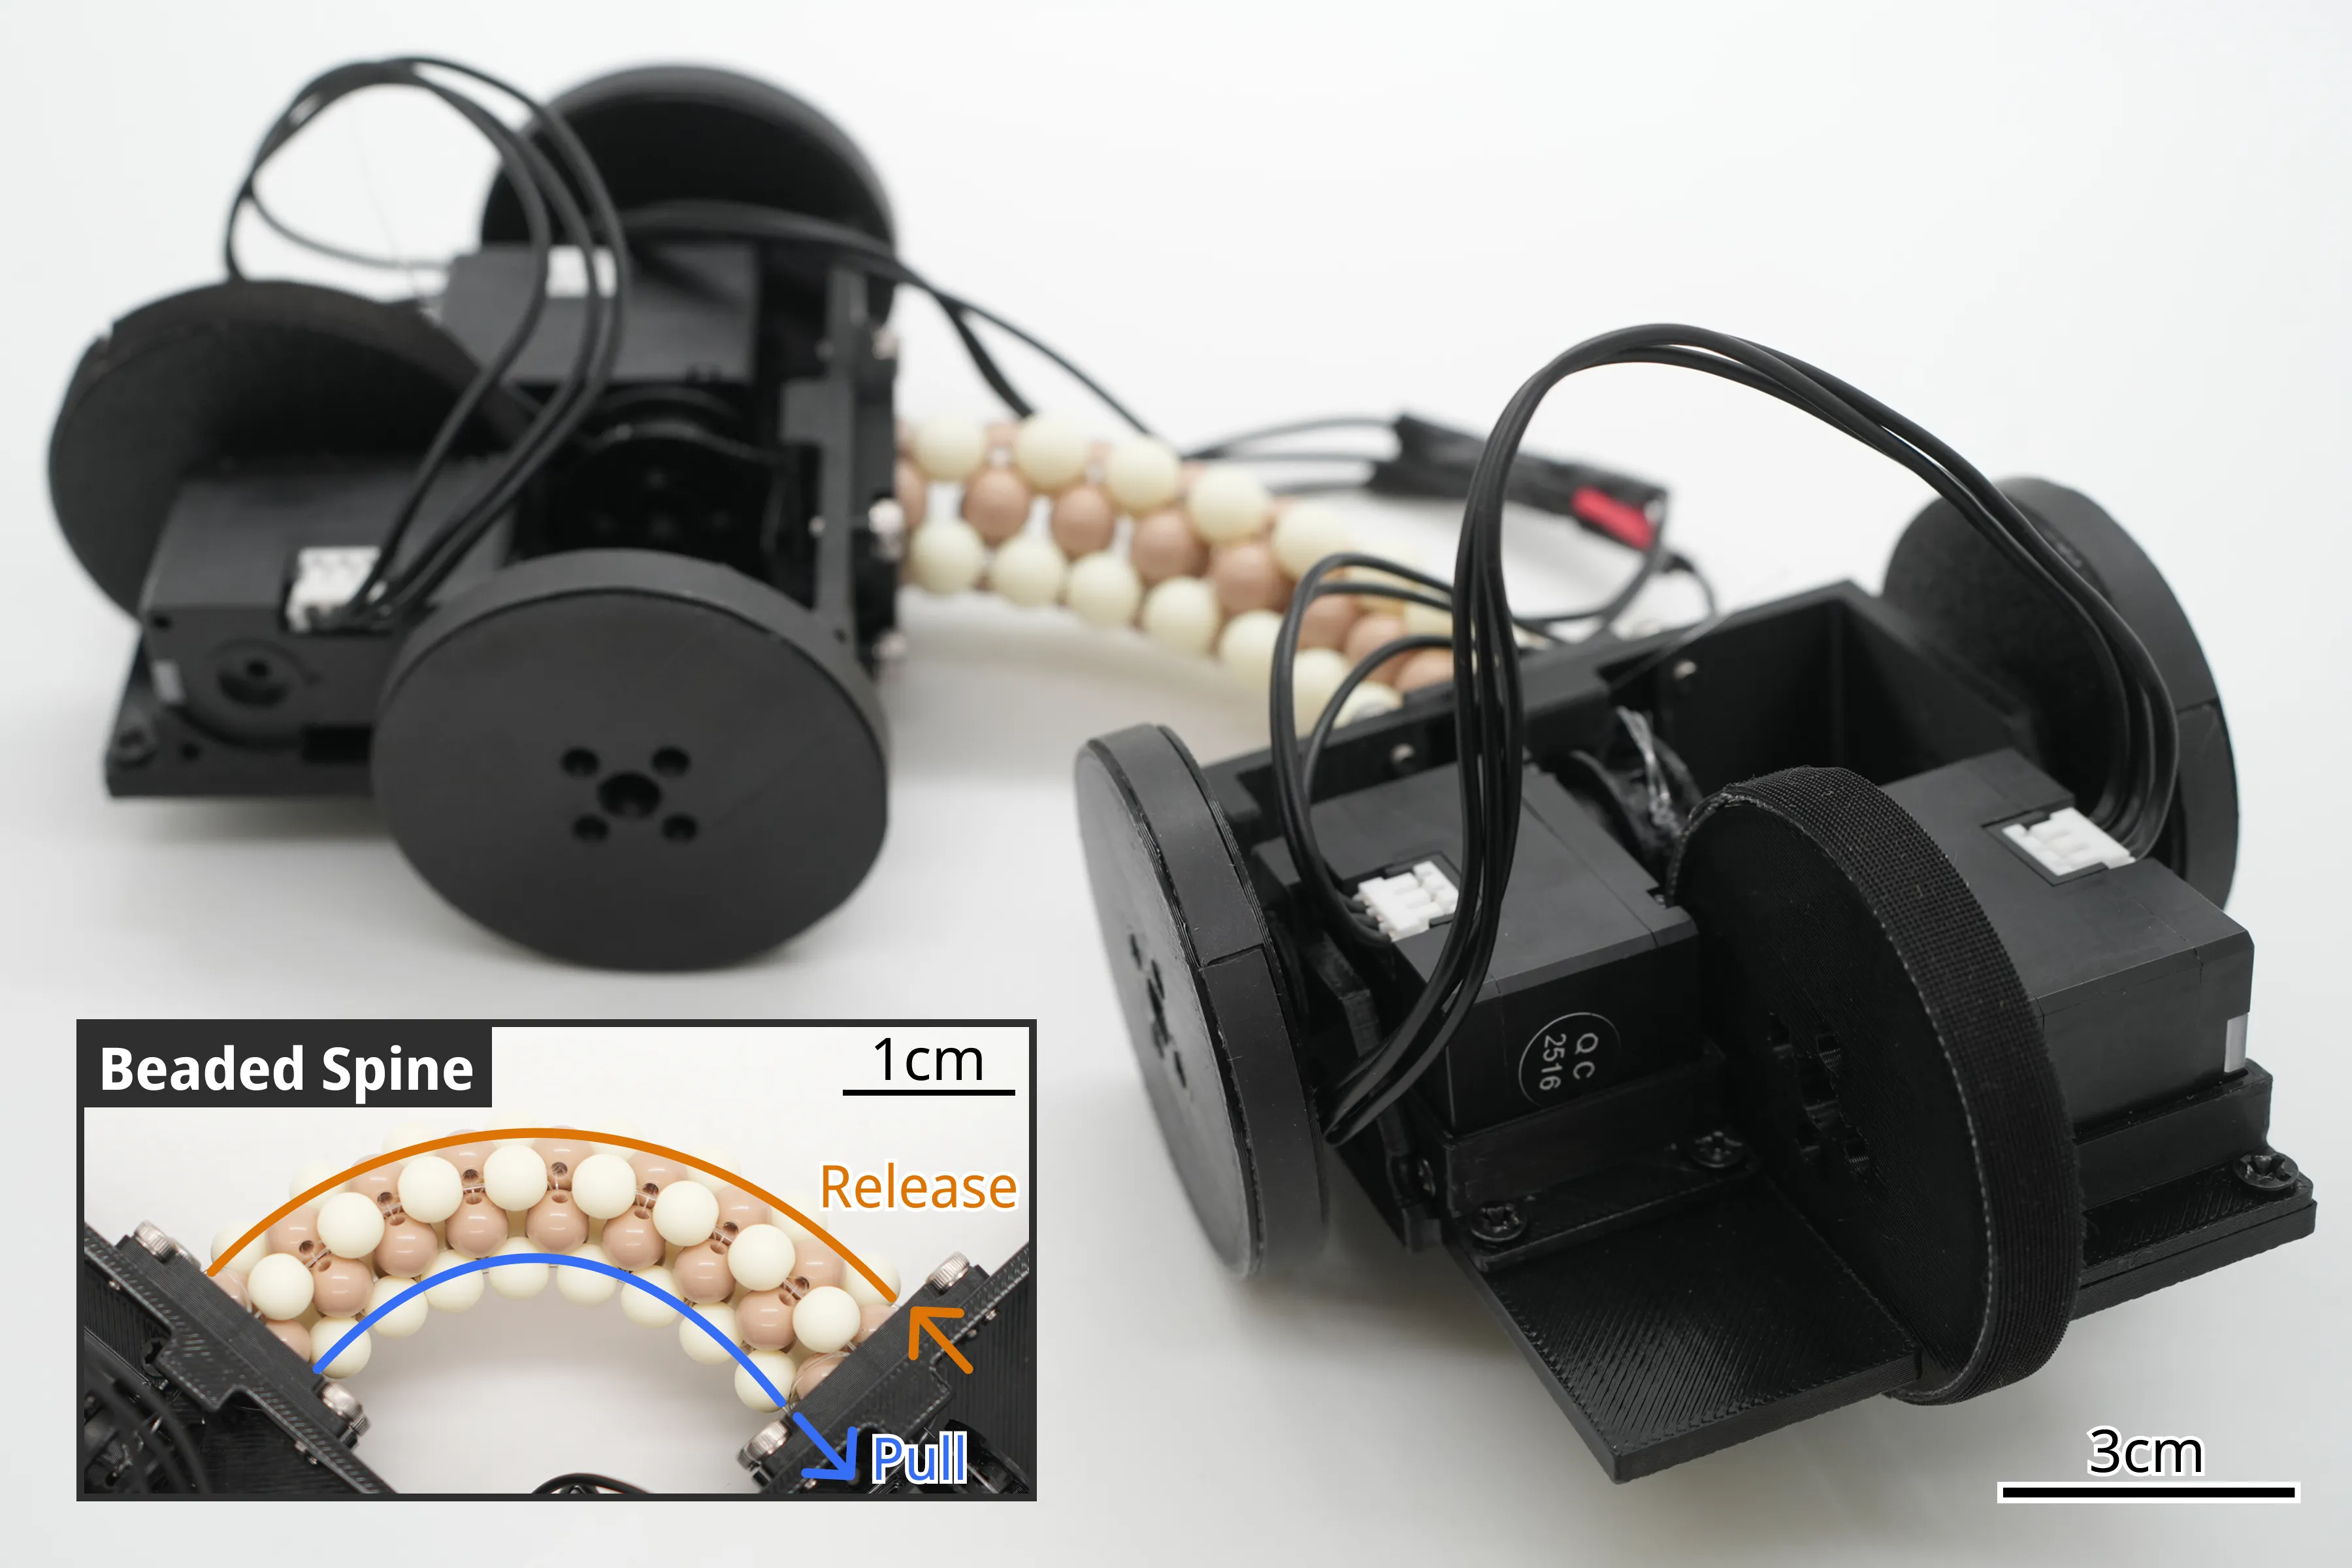
A Tendon-Driven Beaded Spine Robot for Shape-Adaptive Locomotion
When Muscles Think: The Embodied Intelligence of Biological and Robotic Actuation, IROS 2026 Workshop
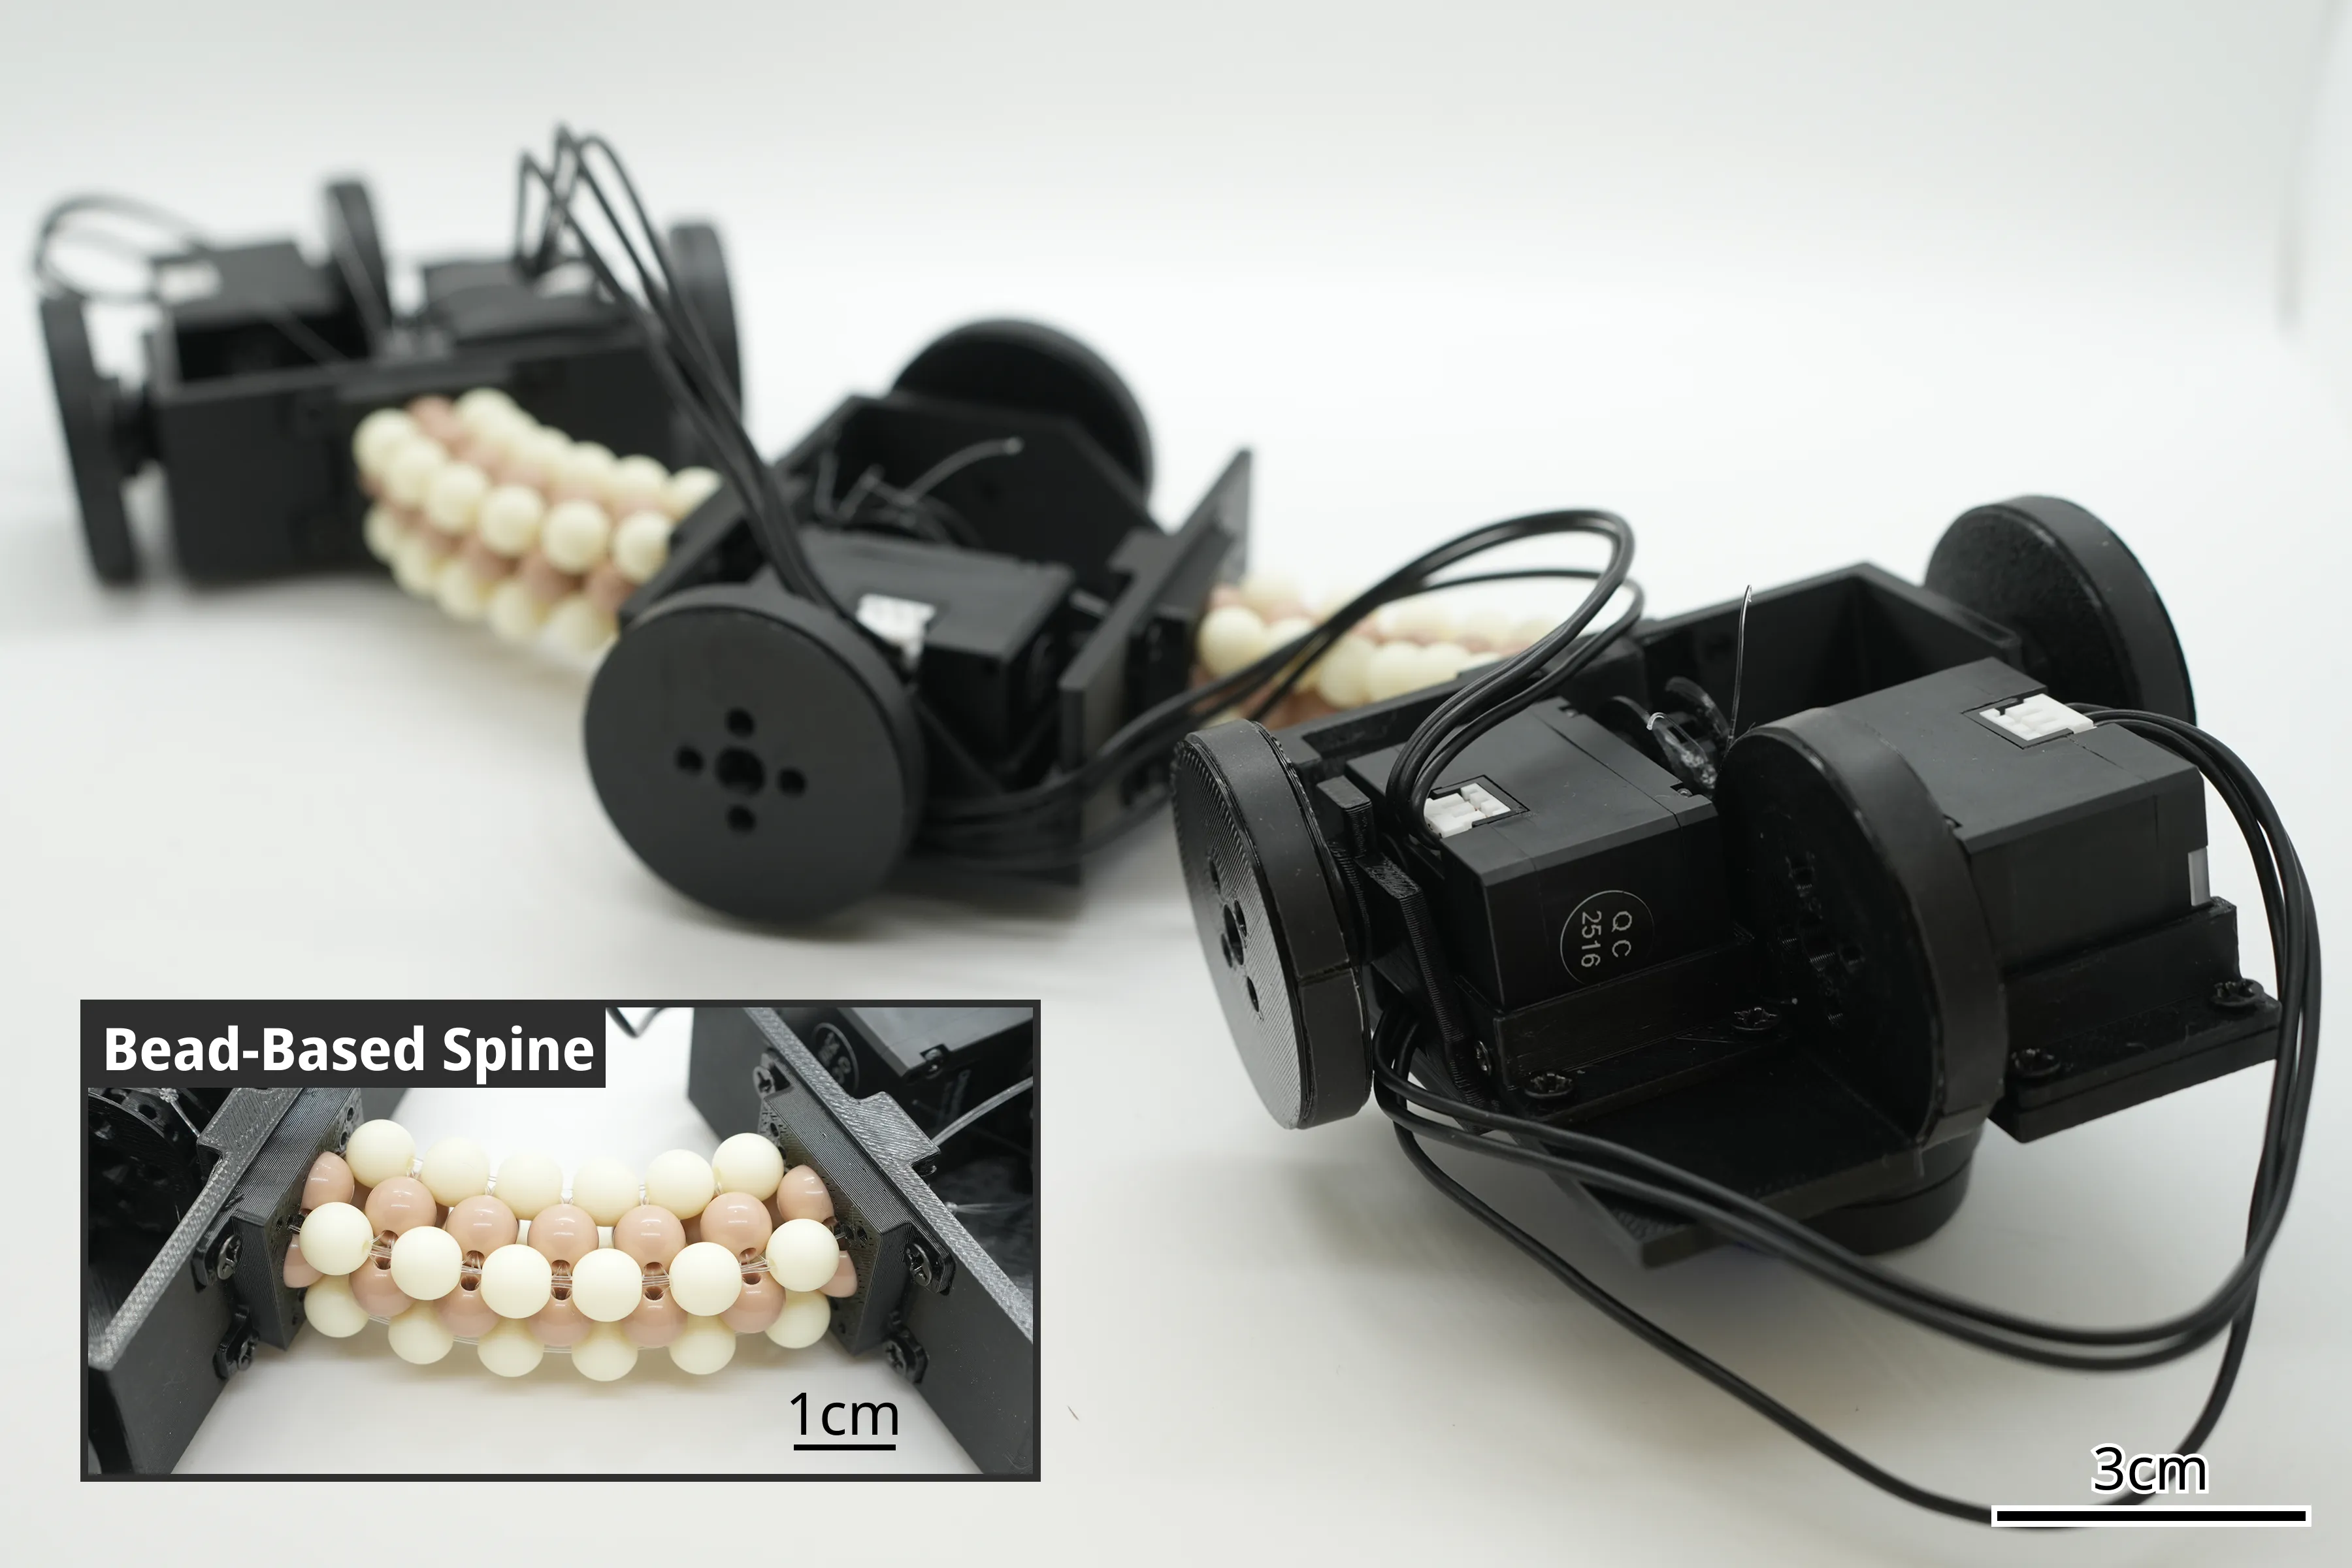
A Tendon-Driven Bead-Based Spine for Shape Adaptive Mobile Robot
Robotics Institute Summer Scholars (RISS) 2026